Projects
Most of this work was built with NTU's robotics teams for the ICRA BARN Challenge and for embodied AI at RoboCup@Home. Team repositories that are still private are marked as such.
Research
VADER — Multi-Robot Navigation in Unknown Environments
Decentralized navigation for robot teams in unknown environments. First-author paper, under review.
VADER on the Robotarium
Real-robot experiments on Georgia Tech's Robotarium.
 No wearables
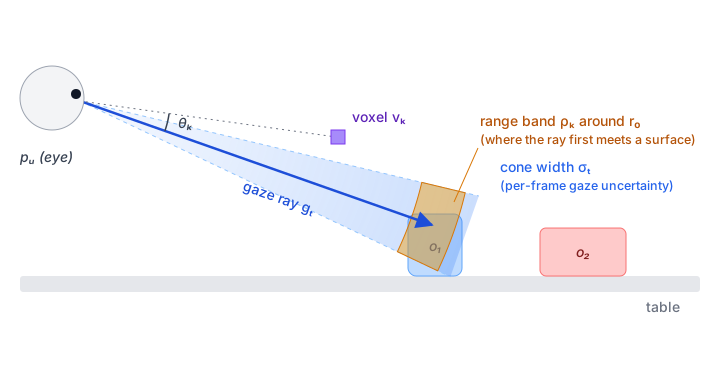
ST-AVL — Gaze Attention Grounding
Toy project with Dr. Shenghai Yuan: which object is a person looking at, from two cheap cameras and no wearables? A Bayesian filter over a 3D voxel grid that answers grounded, uncertain or no attention.
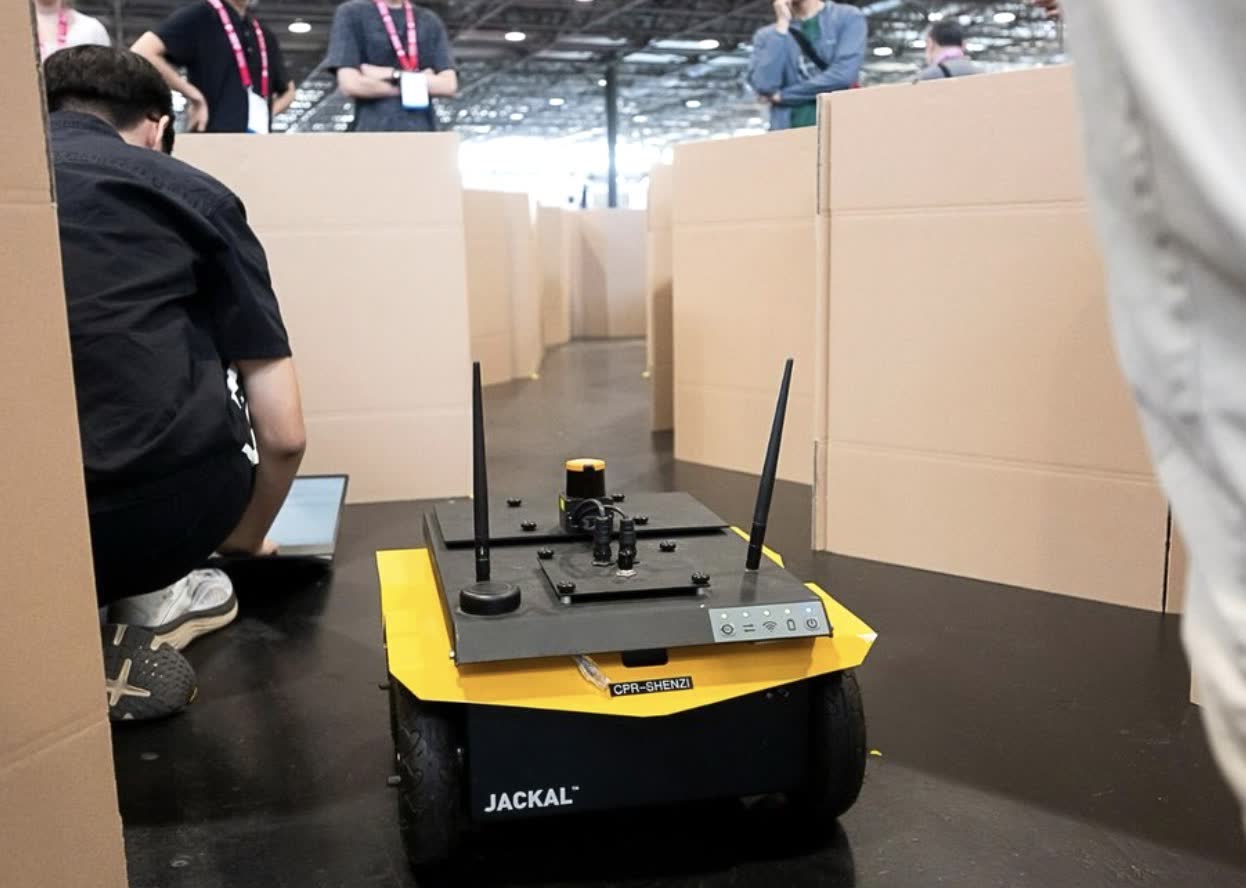
ICRA BARN Challenge 2026
 3rd · ICRA 2026 final
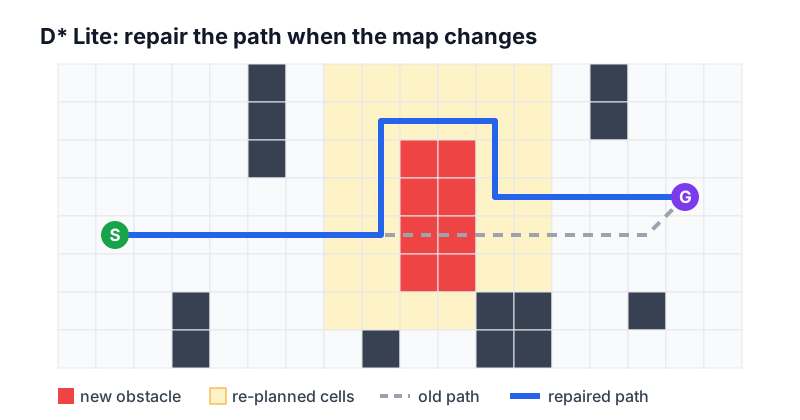
D* Lite Global Planner
Incremental D* Lite global planner plugin for move_base that replans quickly when the map changes.
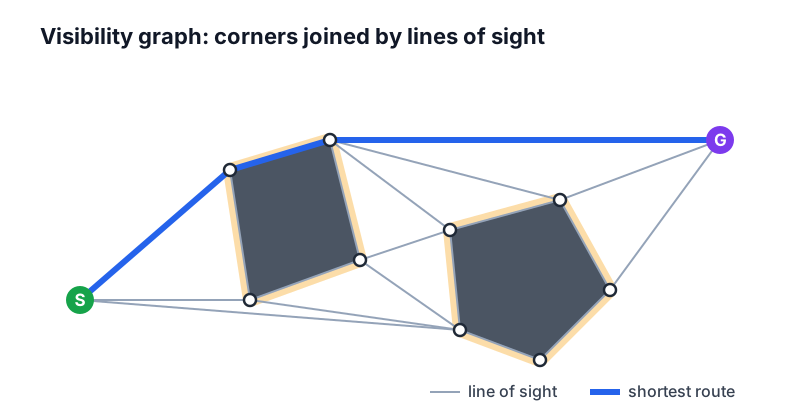
Visibility-Graph Global Planner
move_base global planner that wraps costmap obstacles in polygons, links mutually visible corners and searches for the shortest route, even in unknown maps.
Embodied AI — RoboCup@Home 2027
 CPU-only on Jetson
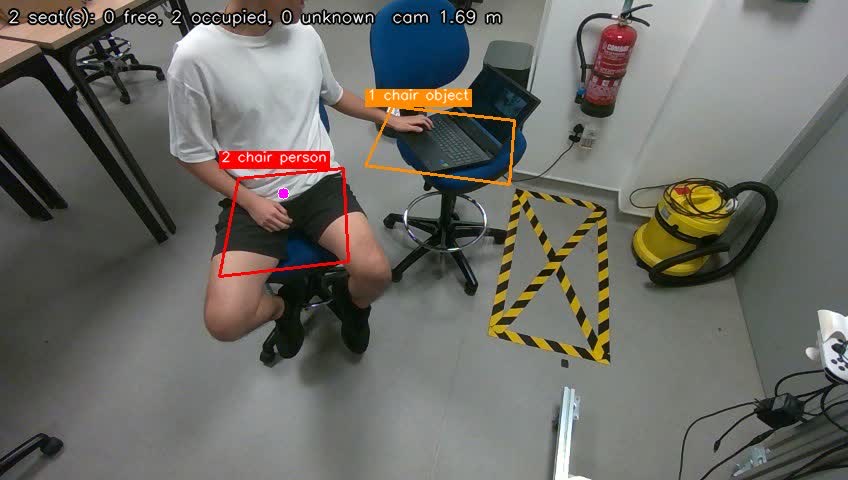
Free-Seat Detection
Finds seats in 3D, remembers them while people hide them, and only offers a seat it is sure is free. CPU only, on the robot's Jetson Orin.
6-DoF Object Pose via MAC Registration
Registers a known object against the live RealSense cloud with maximal-clique registration (CVPR'23). A quality gate rejects doubtful poses.
Offline Speech Commands
On-robot Whisper speech recognition with intent parsing. Returns ACCEPT, CONFIRM or REJECT, so a misheard word costs one confirmation, not a repeat. The robot's face screen reacts as it listens and replies.
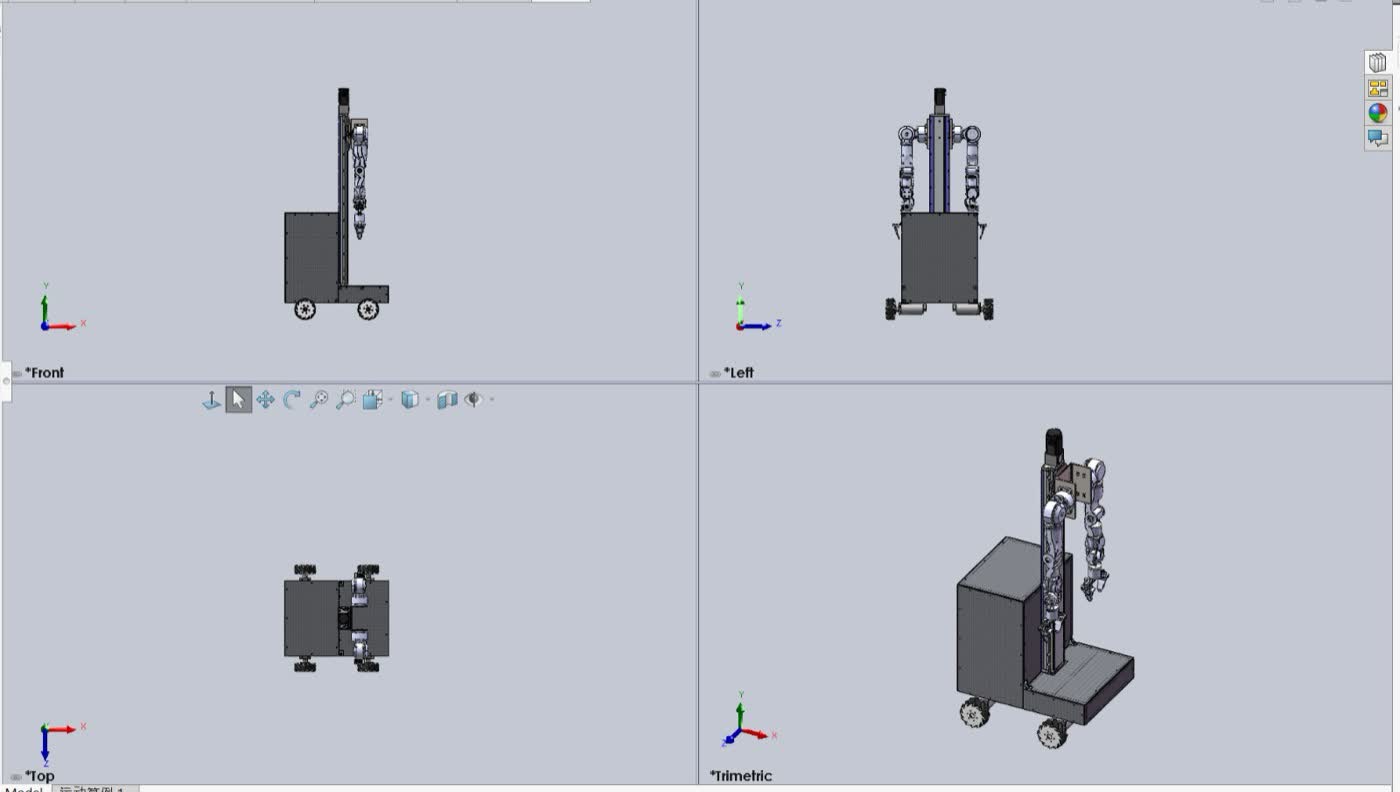
Self-Built Wheeled Humanoid
Hardware by Aqid, Jing Yang and the hardware team: our own robot, with a mecanum base, a vertical lift and two OpenArm arms, alongside the Galaxea R1 we develop on today.
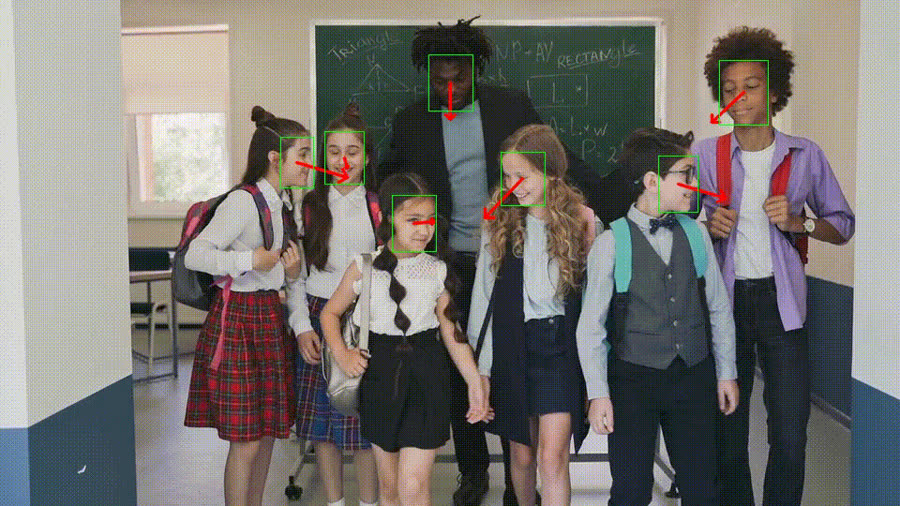
L2CS Gaze Estimation
ROS 2 package for real-time webcam gaze estimation with L2CS-Net (ResNet-50, Gaze360), with RViz gaze-ray visualisation.
Autonomous Maritime Systems — RobotX 2026
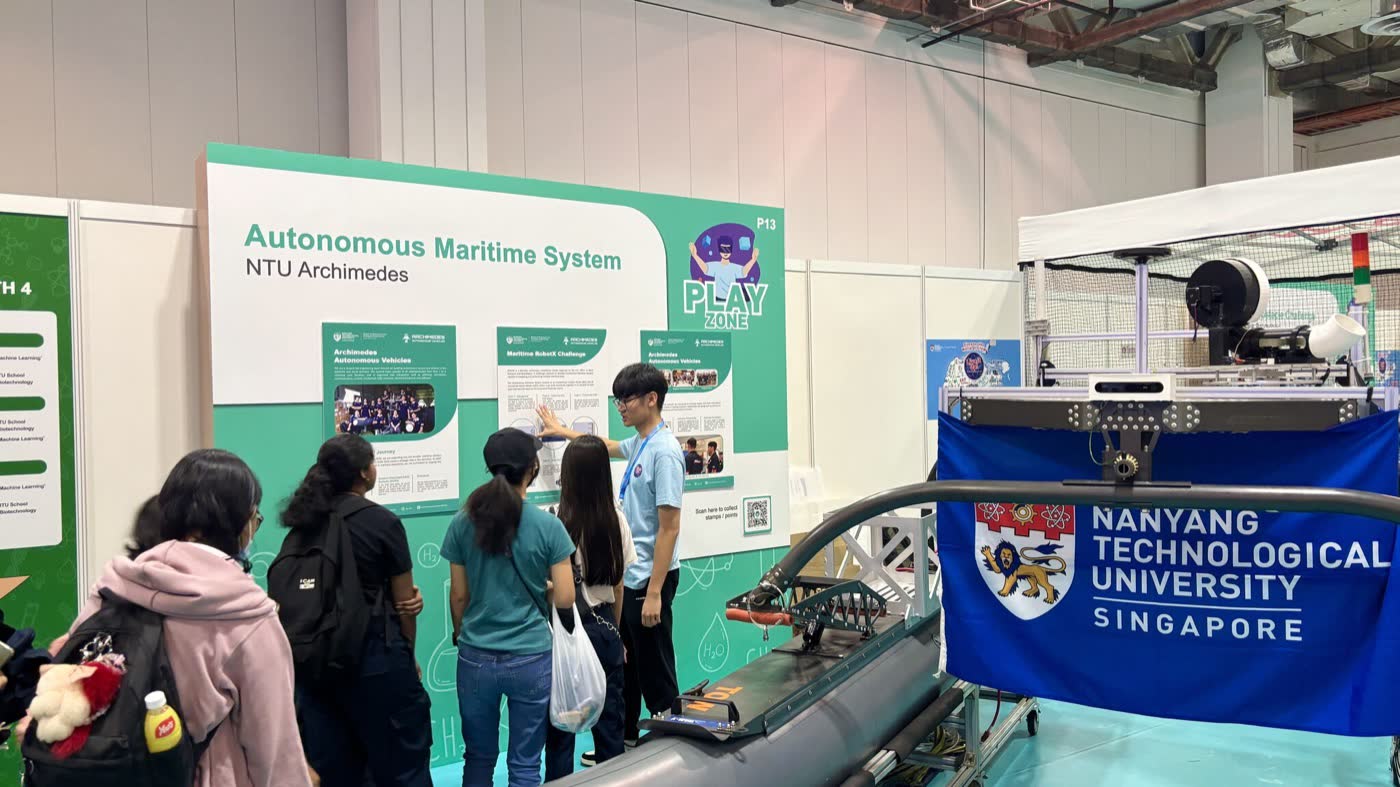
Team Archimedes
NTU's RobotX team, building an autonomous surface vessel and drone. I contributed CAD of electrical components and YOLO perception, and presented the vehicles at an outreach event.
Industry
 ~100% detection, 0 FP
Camera Obstacle Detection (Hyundai)
Covers 2D-LiDAR blind spots with a depth camera: nearly 100% detection, zero false positives, over 15 Hz on CPU.
Robot Self-Occlusion Removal (A*STAR)
PointNet segmentation that removes a UR16e arm from its own point cloud for human–robot collision avoidance: 98.79% accuracy, 98% IoU.
Earlier Projects
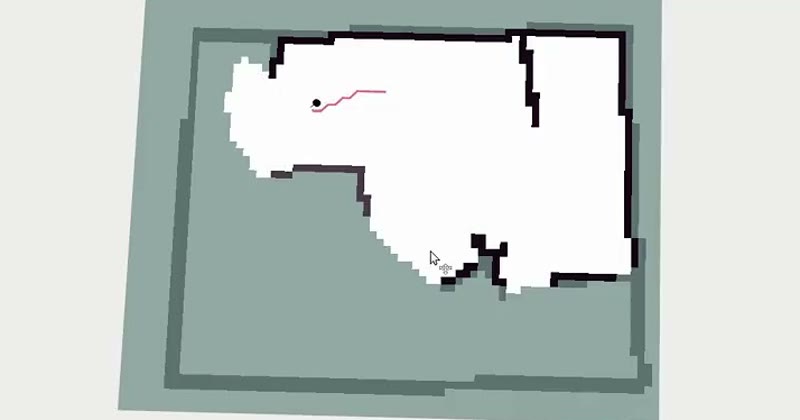
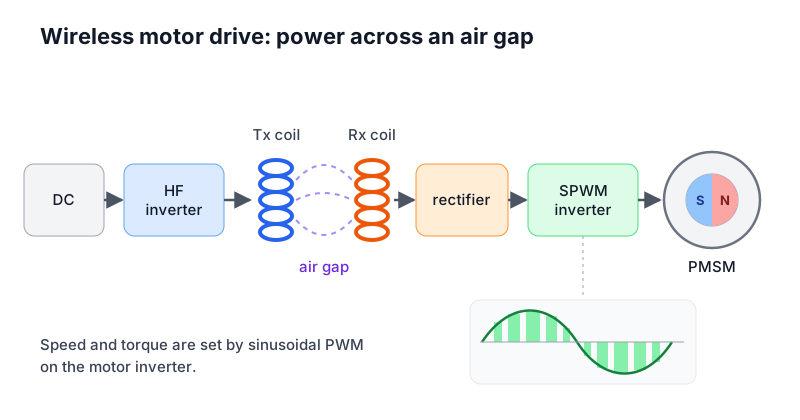
Wireless Motor Drive (URECA)
A simulated inductive wireless power link driving a PMSM with SPWM control. President's Research Scholar.