Dun Yan Ong (Ong Dun Yan)
Final-year Electrical & Electronic Engineering student at NTU Singapore, working on multi-robot systems, scene understanding and robot perception.
News
- Sep 2026Submitted VADER, on decentralized multi-robot navigation in unknown environments, to one of the top IEEE robotics conferences as first author.
- Aug 2026Co-authored the BARN Challenge lessons-learned paper, submitted to IEEE Robotics and Automation Magazine.
- Jun 2026Team Robo placed 3rd in the physical final of the ICRA 2026 BARN Challenge, and 1st all-time in dynamic environments.
- Jun 2026Founded and lead NTU’s 34-member embodied AI team, Singapore’s first RoboCup@Home team, building a home-service wheeled humanoid for RoboCup@Home 2027.
Older news
- Jan 2026Joined Hyundai Motor Group Innovation Center Singapore as a robotics SLAM intern.
- Oct 2025Started research on multi-robot systems at the SJTU Robotics Autonomy and Planning Lab.
- May 2025Joined A*STAR ARTC as a robotics and AI intern, working on scene understanding for human–robot collision avoidance.
- Jan 2025Joined Archimedes Autonomous Vehicles, NTU’s RobotX team, working on electrical CAD design and YOLO perception for the autonomous surface vessel.
- Aug 2024Started undergraduate research on a wireless motor drive with Prof. Christopher H. T. Lee at NTU (URECA), later awarded President’s Research Scholar.
- Jan 2023Joined DoctorOnCall as a software engineering intern, working on LLM and machine learning projects.
Publications
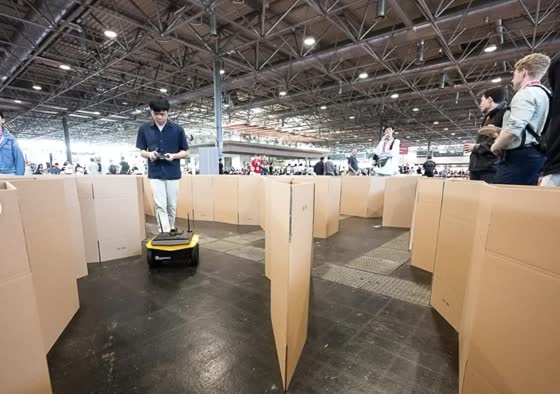
Summary
The organisers' report on the competition, including the approaches of the three winning teams. Our NMPC stack is described in the Team Robo section.
Selected Projects
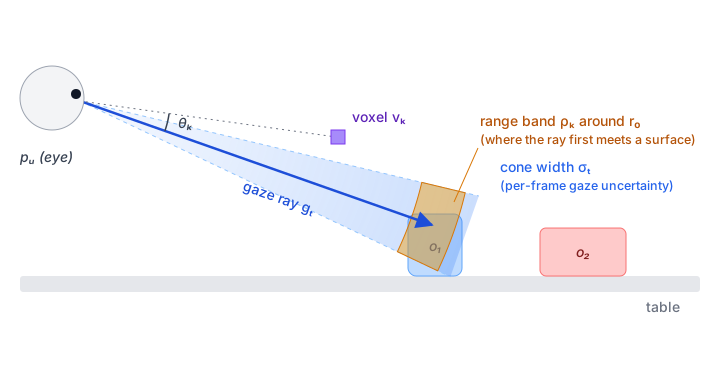
ST-AVL — Gaze Attention Grounding
Toy project with Dr. Shenghai Yuan: which object is a person looking at, from two cheap cameras and no wearables? A Bayesian filter over a 3D voxel grid that answers grounded, uncertain or no attention.
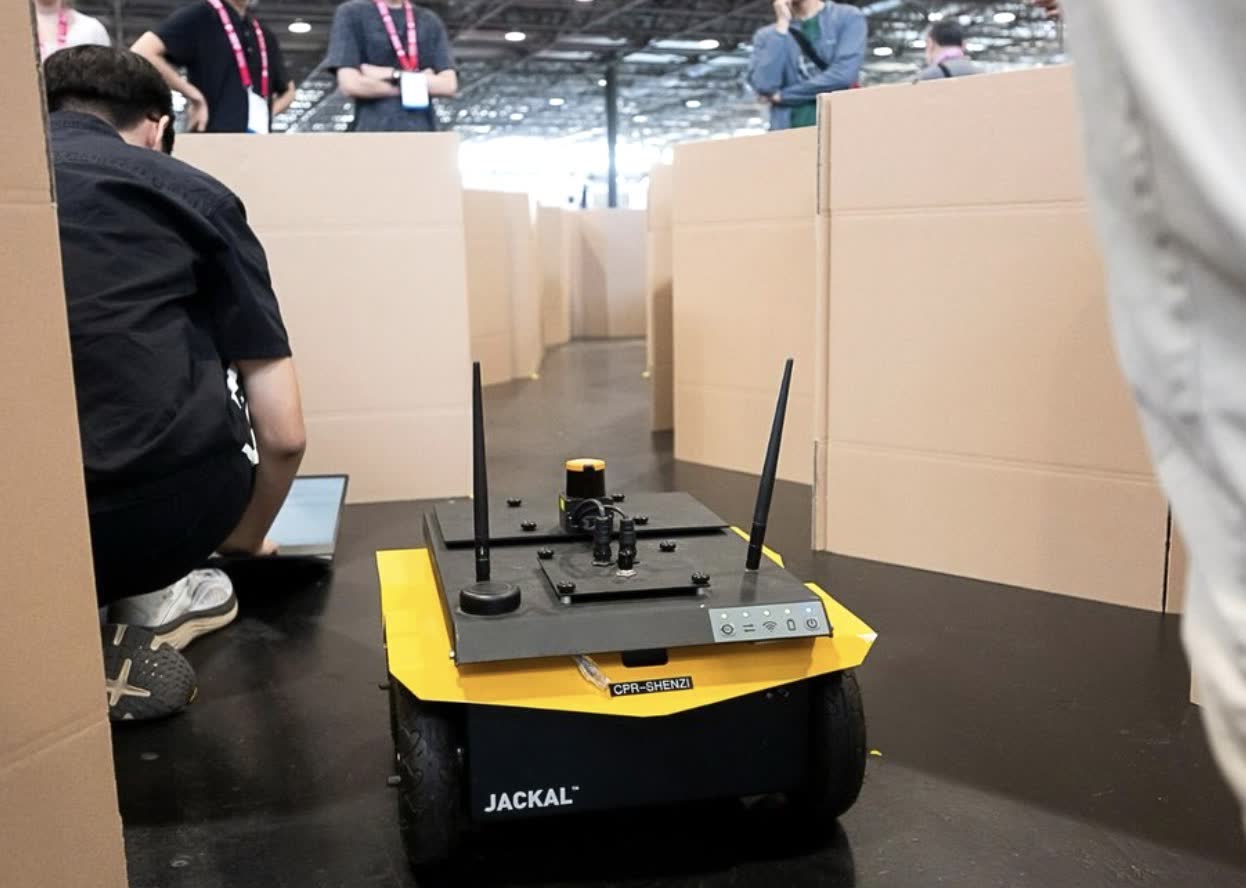
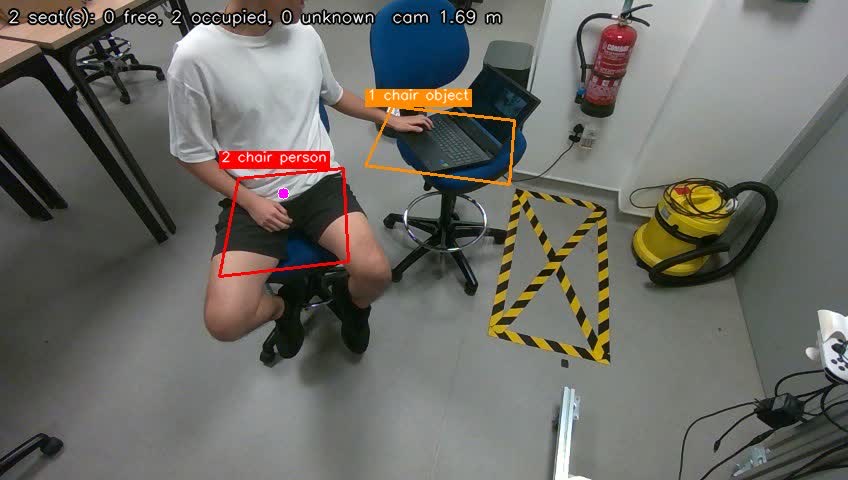
Free-Seat Detection
Finds seats in 3D, remembers them while people hide them, and only offers a seat it is sure is free. CPU only, on the robot's Jetson Orin.
6-DoF Object Pose via MAC Registration
Registers a known object against the live RealSense cloud with maximal-clique registration (CVPR'23). A quality gate rejects doubtful poses.
Offline Speech Commands
On-robot Whisper speech recognition with intent parsing. Returns ACCEPT, CONFIRM or REJECT, so a misheard word costs one confirmation, not a repeat. The robot's face screen reacts as it listens and replies.
Camera Obstacle Detection (Hyundai)
Covers 2D-LiDAR blind spots with a depth camera: nearly 100% detection, zero false positives, over 15 Hz on CPU.
Experience
Built VADER, a decentralized multi-robot navigation framework for unknown environments (first-author paper, under review).
Details
- Supervised by Prof. Zhongqiang (Richard) Ren, co-supervised by Dr. Shenghai Yuan.
- Developing VADER, decentralized multi-robot navigation in unknown environments, as first author (paper under review).
Camera-based obstacle detection covering 2D LiDAR blind spots: near-100% detection, zero false positives, >15 Hz on CPU.
Details
- Researched real-time camera-based obstacle detection with Orbbec Gemini 2 and Femto Bolt to cover 2D LiDAR blind spots (>15 Hz, CPU only).
- Achieved nearly 100% detection success with zero false positives across floor conditions.
- Worked on Cartographer SLAM, AMCL localisation and Nav2 navigation testing; reported trade-off analyses to Korea HQ.
Scene understanding for human–robot collision avoidance: PointNet segmentation for robot occlusion removal on a UR16e, 98.79% test accuracy, 98% IoU.
Details
- Designed and deployed scene-understanding algorithms on ZED 2i point clouds.
- Trained a PointNet (PyTorch) segmentation model for robot occlusion removal: 98.79% test accuracy, 98% IoU on a custom 583-sample dataset.
- Used forward and inverse kinematics to generate UR16e arm meshes and align them with point clouds in PCL.
Led the ICRA BARN navigation team (3rd in the physical final). Separately, founded Singapore’s first RoboCup@Home team (34 members).
Details
The team began as the MLDA@EEE Robo Team and is now an independent student team, which streamlines university approvals for external robotics competitions. We continue to value its roots in MLDA@EEE.
- Led an 8-member team on autonomous navigation for the IEEE ICRA BARN Challenge 2026: 1st all-time in dynamic environments, 6th in static environments, 3rd in the physical final.
- Founded and lead a 34-member embodied AI team, Singapore’s first RoboCup@Home team, building a home-service wheeled humanoid for RoboCup@Home 2027 (write-up).
Electrical CAD design and YOLO perception for NTU’s autonomous surface vessel.
Details
- Worked on real-time YOLO object detection for the autonomous surface vessel.
- CAD design of electrical components.
- Presented the team’s ASV and UAV to students at NTU’s Live It Up! STEM showcase (Aug 2025).